Robotics · The University of Texas at Austin

Dong Ho Kang

Robotics PhD Student

I am a Ph.D. student at UT Austin, advised by Dr. Luis Sentis in the Human Centered Robotics Lab. My research focuses on Contact Morphology Design for dexterous manipulation. I design geometry, compliance, transmission, and sensing at the contact interface to make physical interaction predictable, observable, and exploitable by the controller.

Dong Ho Kang
Contact Morphology Design
Dexterous manipulation · Robot control

Research

Selected publications

All publications ↗
PLATO Hand: Shaping Contact Behavior With Fingernails for Precise Manipulation research preview

2026

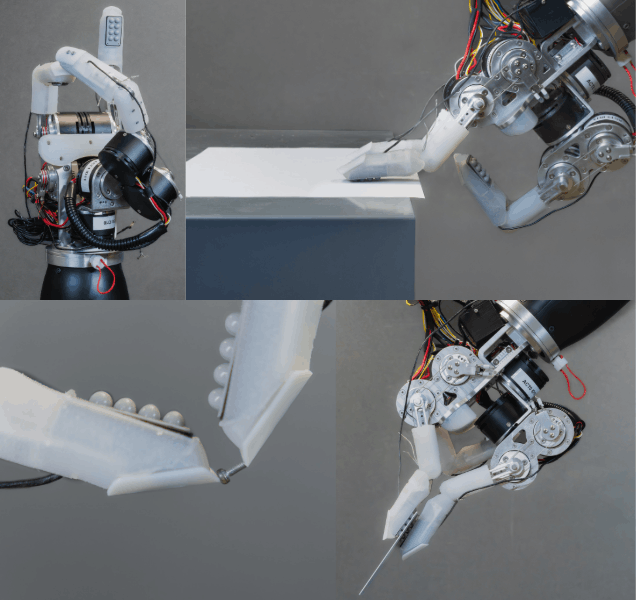
PLATO Hand: Shaping Contact Behavior With Fingernails for Precise Manipulation

Dong Ho Kang, Aaron Kim, Mingyo Seo, Kazuto Yokoyama, Tetsuya Narita, Luis Sentis

IEEE Robotics and Automation Letters

Media coverage: Science News ↗

My contribution

Led the project from core concept to manuscript, with contributions in hardware implementation, experimental design, result interpretation, and writing.
LUMO: Designing Luminous Contact Morphology for Repeatable Whole-Finger Contact Observation research preview

2026

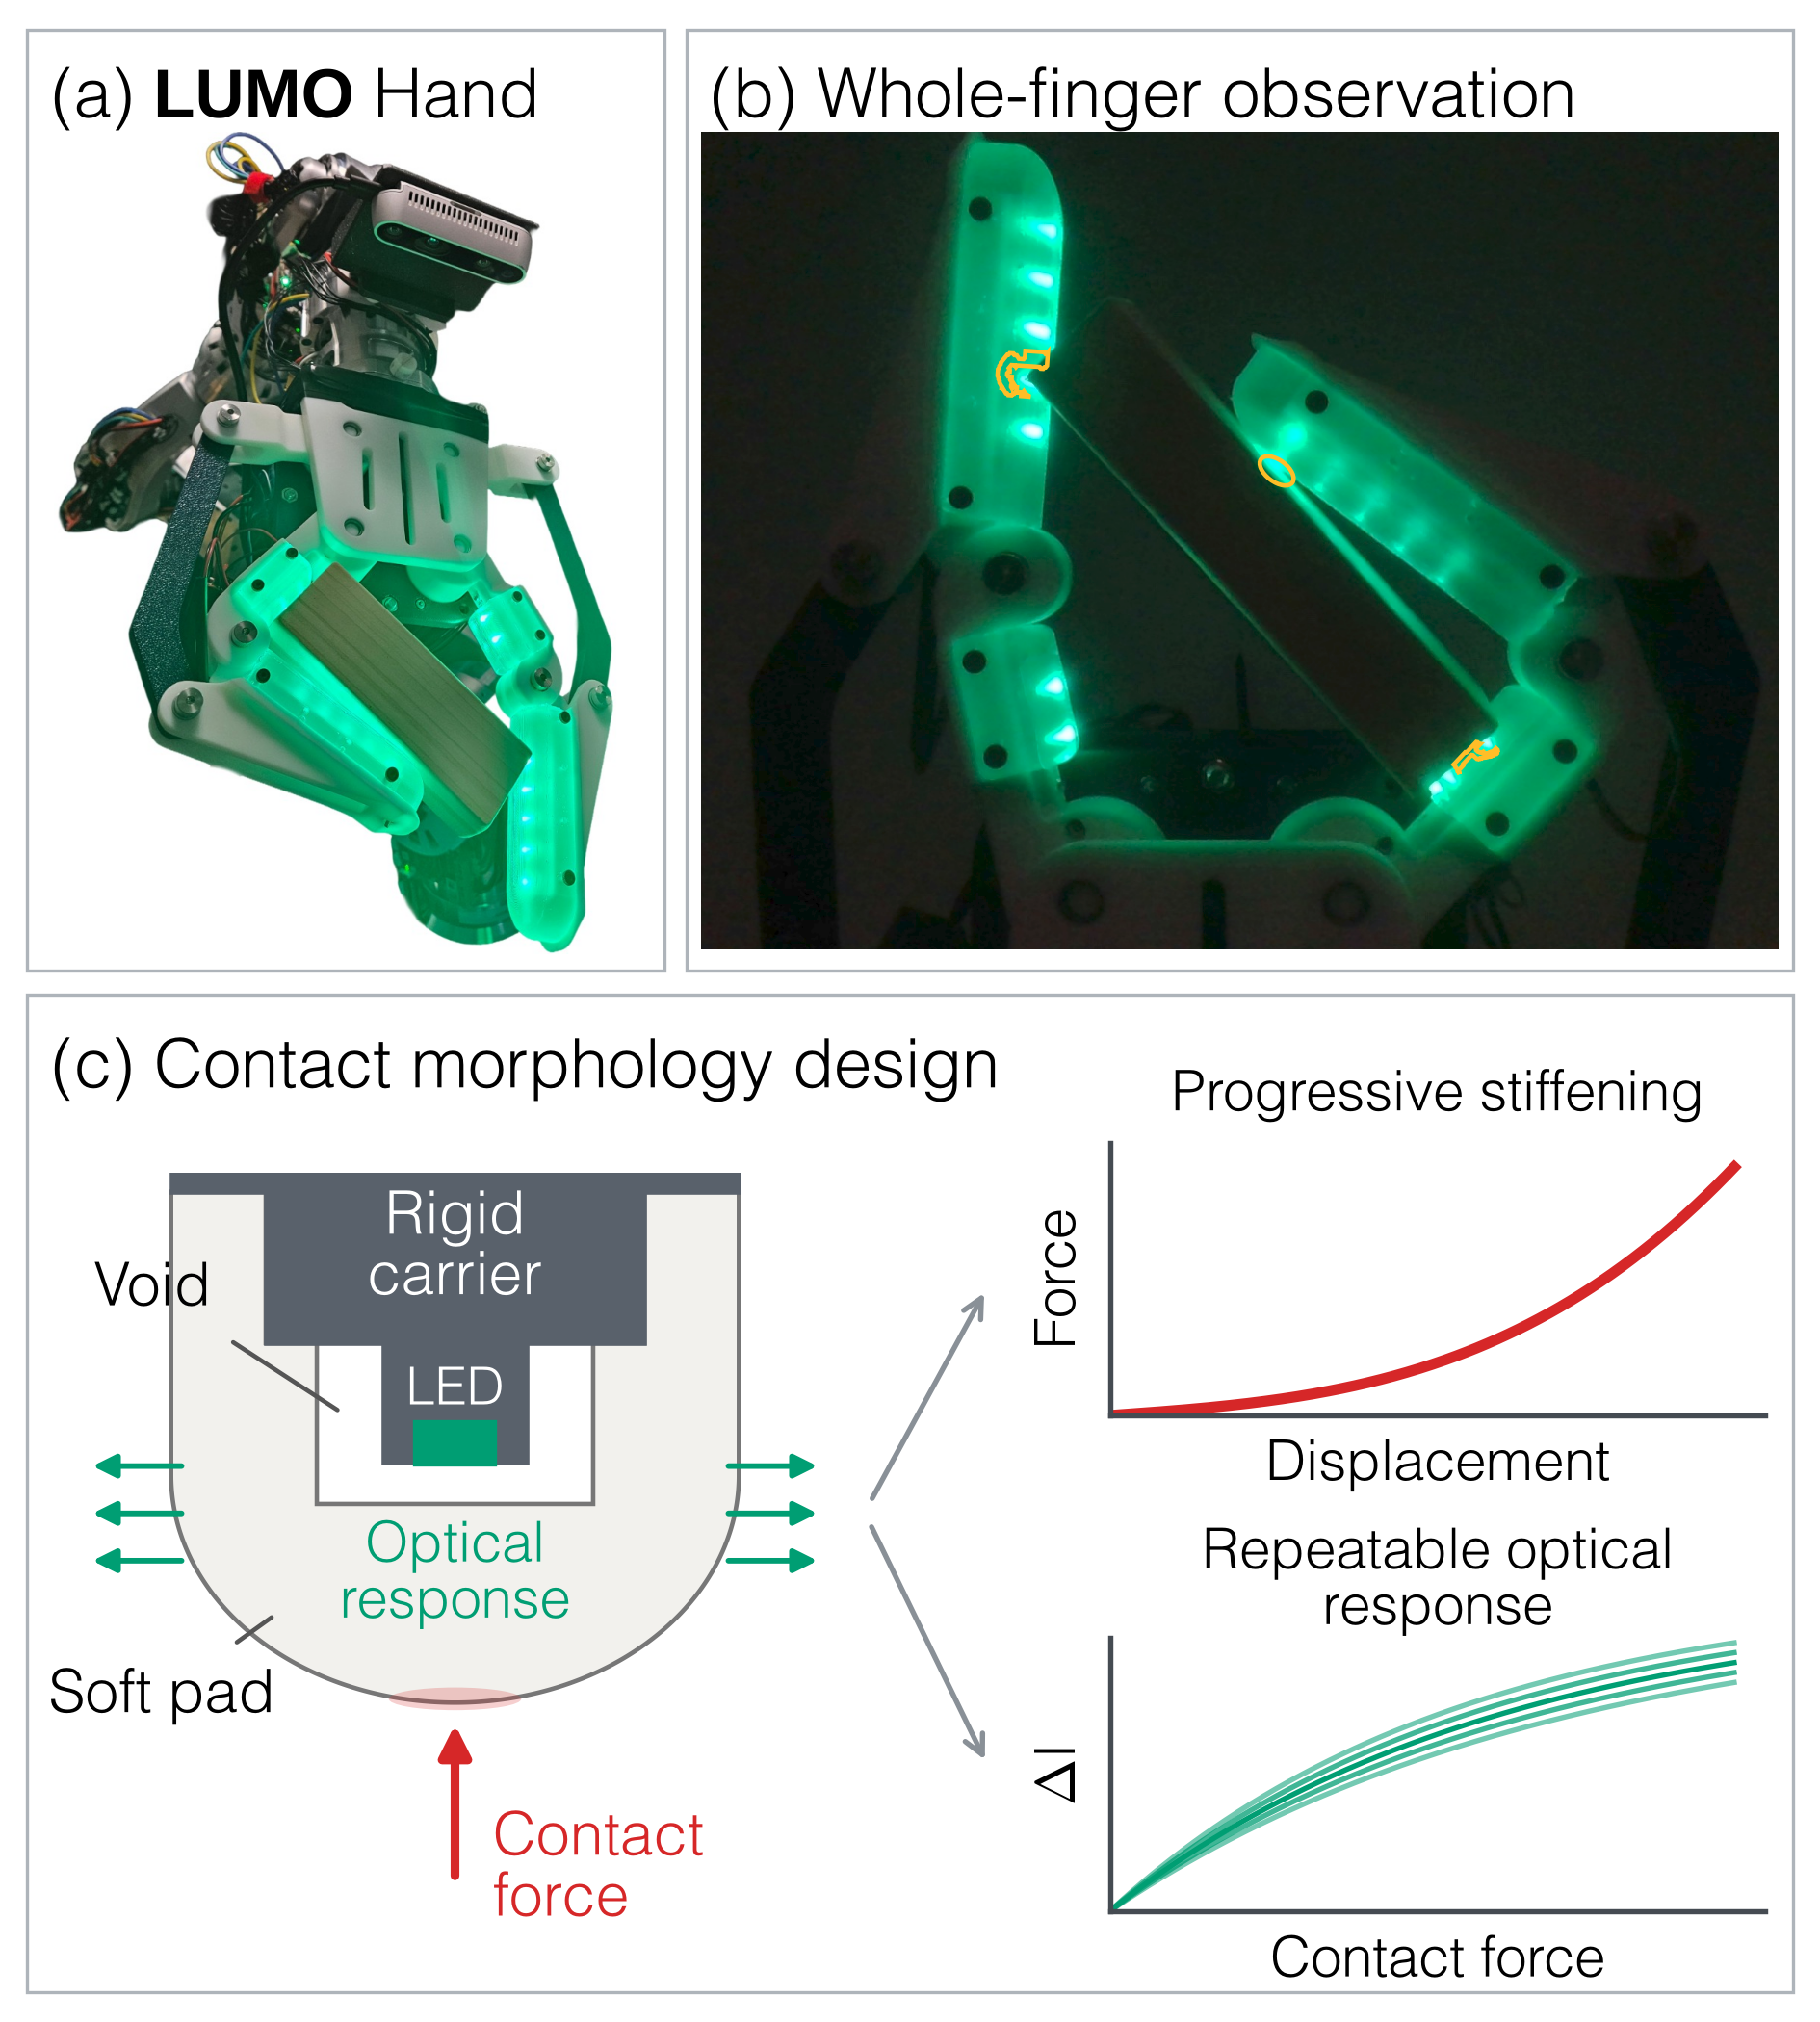
LUMO: Designing Luminous Contact Morphology for Repeatable Whole-Finger Contact Observation

Dong Ho Kang, Youngsu Ko, Luis Sentis

My contribution

Led the project from contact-morphology design and simulation through experimental evaluation and manuscript preparation.

ARISTO Hand: Sensing-Driven Distal Hyperextension for Fine-Grained Manipulation research preview

2026

ARISTO Hand: Sensing-Driven Distal Hyperextension for Fine-Grained Manipulation

Aaron Kim, Dong Ho Kang, Mark Helwig, Mingyo Seo, Kazuto Yokoyama, Tetsuya Narita, Luis Sentis

2026 IEEE/ASME International Conference on Advanced Intelligent Mechatronics (AIM)

Media coverage: IEEE Spectrum ↗

My contribution

Embedded system, low-level control, and system integration.

Updates

News

Notes from research

Latest writing

Blog ↗